Understanding Windowing And Overlapping Analysis
[latexpage]The following article was inspired by a question asked by a reader regarding my previous article - Data Windows : What, why and when?. Specifically, the reader asked "Could you please…
[latexpage]The following article was inspired by a question asked by a reader regarding my previous article - Data Windows : What, why and when?. Specifically, the reader asked "Could you please…
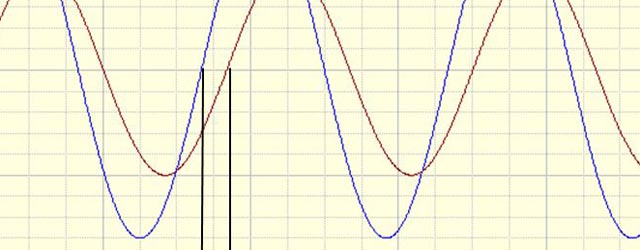
In one of our recent articles a question was asked regarding the practical use of real & imaginary type plots compared with modulus & phase type plots. In general, noise…
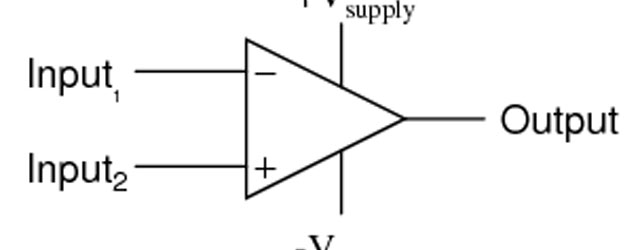
Prosig data acquisition systems use differential inputs, but what are they and why are they so special? This subject is not always fully understood and, therefore, the focus of this…
From time to time I meet engineers who are interested in the conversions between acceleration, velocity and displacement. Often, they have measured acceleration, but are interested in displacement or vice versa. Equally, velocity is often used to find acceleration. This article outlines the nature of the conversion between these units and will suggest the preferred method for doing so. .
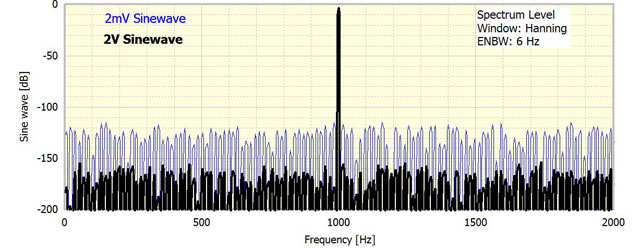
At least one manufacturer of data acquisition systems claims to achieve an incredibly high dynamic range (160dB) when capturing data. This is supposedly achieved by the use of dual-range data acquisition architecture. Such systems have two analog-to-digital convertors for each input channel; one of the ADCs captures the full voltage range of the input signal and the other ADC captures the input signal only when it is small. This article explains the facts behind the figures and shows that the use of Dynamic Range as a measure of precision can be misleading.

Creating a good quality tachometer signal is one of the hardest parts of analyzing rotating machinery. So what happens if we have missing tachometer pulses? The data looked great until we tried to perform some in-depth torsional vibration analysis. And now we no longer have the component or vehicle to retest it. Do we have to scrap the whole test? Was all that time wasted? Not necessarily…
An investigation was made of a sample of automotive components where some were exhibiting a high frequency “tick” or rattle during each operating cycle. This feature could be heard above the normal operating noise. The problem this posed was to measure and analyze components in an objective fashion and classify components as “good” or “bad”.
It sometimes occurs that signals are captured with A-weighting applied to the data by the acquisition device. This can be a problem if, for example, you wish to use the data in a hearing test or to use it for a structural vibration analysis. Now, A-weighting allegedly mimics what the ear does to a signal. If we play back an A weighted sound then we perceive a double A-weighted signal which is clearly not intended. When doing structural work it is usually the lower frequencies, say 2kHz or less, that is generally required. A-weighting seriously attenuates the low frequencies and also applies gain above 1kHz.

These days most people collecting engineering and scientific data digitally have heard of and know of the implications of the sample rate and the highest observable frequency in order to avoid aliasing. For those people who are perhaps unfamiliar with the phenomenon of aliasing then an Appendix is included below which illustrates the phenomenon.
In saying that most people are aware of the relationship concerning sample rate and aliasing this generally means they are aware of it when dealing with constant time step sampling where digital values are measured at equal increments of time. There is far less familiarity with the relevant relationship when dealing with orders, where an order is a multiple of the rotational rate of the shaft. For example second order is a rate that is exactly twice the current rotational speed of the shaft. What we are considering here then is the relationship between the rate at which we collect data from a rotating shaft and the highest order to avoid aliasing.
The relationship depends on how we do our sampling as we could sample at constant time steps (equi-time step sampling), or at equal angles spaced around the shaft (equi-angular or synchronous sampling). We will consider both of these but first let us recall the relationship for regular equi-time step sampling and the highest frequency permissible to avoid aliasing. This is often known as Shannons Theorem [Learn more about Claude E Shannon].
(more…)
 This note is based on a real requirement presented to Prosig by a prospective user. It’s the sort of challenge that we relish. This case is a great example of a real-world signal processing requirement and also great test of some of the unique features of Prosig’s DATS software. It also shows the power and flexibility of the new DATS V7.0 worksheets.
Road noise (the noise produced by the interaction of tires and road surface) is in many circumstances the dominant noise experienced by vehicle occupants. The requirements for producing quieter roads…

The following article will attempt to explain the basic theory of the frequency response function (FRF). This basic theory will then be used to calculate the frequency response function between two points on a structure using an accelerometer to measure the response and a force gauge hammer to measure the excitation.
Fundamentally a FRF is a mathematical representation of the relationship between the input and the output of a system.
(more…)
Amplitude and energy correction has been and is a continuing point of confusion for many people calculating spectra from time domain signals using Fourier transform methods. The first thing to say, the information contained in data presented as amplitude and energy corrected spectra is equivalent. The only difference is the scaling of the numbers calculated.
Before we discuss the use of data windows, we should first remind ourselves of three basic properties of the FFT (Fast Fourier Transform) process.
These are two different techniques aimed at different objectives. First consider a simple sinewave that has been sampled close to the Nyquist frequency (sample rate/2).

Visually this looks very pointy. We will examine it using a filter based interpolation and a classical curve fitting procedure to obtain a better representation.

 Knowing how to measure torsional vibration is of key importance in the area of vehicle development and refinement. The main contributory source is the engine where periodically occurring combustion cycles cause variation in the crankshaft rotary vibration. This vibration is transmitted to and modified further by other components in the powertrain such as the gearbox and by other equipment driven off the drive belt or chain. Additional torsional vibrations are also likely to appear downstream at the drive shafts and wheels.
Shaft displacement is an important vibration measurement for rotating machines. Shaft displacement is usually monitored by non-contact shaft displacement probes such as eddy-current probes. These probes produce a voltage proportional to the distance of the shaft surface relative to the tip of the probe. For maximum benefit, ideally two shaft displacement probes will be fitted to measure the displacement in both the horizontal and vertical directions. Actually the probes do not have to be exactly horizontal and vertical as Prosig’s PROTOR system is able to resolve into the horizontal and vertical directions.
Any vibration signal may be analyzed into amplitude and phase as a function of frequency. The phase represents fifty percent of the information so it is most important to measure phase for vibration monitoring. Most vibrations on a rotating machine are related to the rotational speed so it is clearly important to have a measure of the speed, either directly or as a once per revolution tacho pulse. A question sometimes arises as to whether a once per revolution tacho reference signal is needed to measure phase. Is it possible to get phase if we only have a speed signal? This note gives some insight into those questions.
Actually the question that should be asked is – “Can we measure a meaningful phase, for use in vibration monitoring, if we only have a speed signal as well as the vibration signals?”

Standards DIN 4150-2:1999-06 and DIN 45669-1:1995-06 provide a means of assessing the effect on human beings of vibration caused by vehicle traffic, trains both above and below ground, construction work and occasional impulsive type vibration caused by, say, blasting and the like.
DIN 45669-1 describes the signal processing actions and DIN 4150-2 details how these are used. Provisions are included for day or night levels and for five categories of building:
By combining a speed signal with a data signal and using the Short Time FFT algorithm (Hopping FFT), it is possible to extract order data directly as a function of time (Orders from Hopping FFT) rather than as a function of speed (Waterfall). This is very useful when analyzing a complete operational cycle which includes run ups, rundowns and periods at operational speeds.

It is quite straightforward to apply “classical” integration techniques to calculate either a velocity time history from an acceleration time history or the corresponding displacement time history from a velocity time history. The standard method is to calculate the area under the curve of the appropriate trace. If the curve follows a known deterministic function then a numerically exact solution can be found; if it follows a non-deterministic function then an approximate solution can be found by using numerical integration techniques such as rectangular or trapezoidal integration. Measured or digitized data falls in to the latter category. However, if the data contains even a small amount of low frequency or DC offset components then these can often lead to misleading (although numerically correct) results. The problem is not caused by loss of information inherent in the digitisation process; neither is it due to the effects of amplitude or time quantisation; it is in fact a characteristic of integrated trigonometric functions that their amplitudes increase with decreasing frequency.

The requirement was to develop a ‘standard’ test for assessing vehicle power steering pump noise (and sound quality). Measurements needed to be objective so that the method would be suitable…

Using Prosig’s P8000 series data acquisition system with DATS signal analysis software, torsional analysis (crank shaft jitter) was performed on an automotive engine attached to an engine dynamometer. The significance of this is that only one tachometer channel was required to identify crank jitter.
(more…)
We hear the word used a lot, but what is resonance? First, in order to explain we have to explain the terms we will use.

Prosig were recently involved in the validation of a closed loop control system for an automotive pump supplier. The customer has a large number of test cells, each test cell has 8 pumps continually on test. Each pump is instrumented with a revolution or tachometer sensor, giving a once per revolution tachometer pulse. Additionally, there are various analogue transducers on each pump which measure parameters, such as pressure at the pump inlet and outlet.